Leader State
LeaderState
ID 563Periodic
- Payload
- ≥ 83 bytes, variable
- Packet
- ≥ 105 bytes
- Source
- vehicle
- Category
- Plan Supervision
This message defines the formation leader state.
LeaderState is a complete description of the leader state in terms of parameters such as position, orientation and velocities at a particular moment in time.
The system position is given by a North-East-Down (NED) local tangent plane displacement (x, y, z) relative to an absolute WGS-84 coordinate (latitude, longitude, height above ellipsoid).
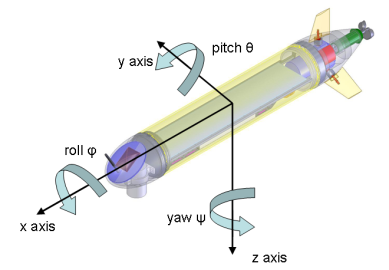
The symbols for position and attitude as well as linear and angular velocities were chosen according to SNAME's notation (1950). The body-fixed reference frame and Euler angles are depicted next:
:align: center
Euler angles
#Fields
| Offset | Field | Type | Unit | Range | Description | |||||||||
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| 0 | #group_nameGroup Name |
plaintext |
– | – | Name for the formation group. |
|||||||||
| var | #opAction on the leader state |
uint8_t |
Enumerated | – | Action on the formation leader state variables
|
|||||||||
| var | #latLatitude (WGS-84) |
fp64_t |
rad | −π/2 … π/2 | WGS-84 Latitude. |
|||||||||
| var | #lonLongitude (WGS-84) |
fp64_t |
rad | −π … π | WGS-84 Longitude. |
|||||||||
| var | #heightHeight (WGS-84) |
fp32_t |
m | – | Height above the WGS-84 ellipsoid. |
|||||||||
| var | #xOffset north |
fp32_t |
m | – | The North offset of the North/East/Down field with respect to LLH. |
|||||||||
| var | #yOffset east |
fp32_t |
m | – | The East offset of the North/East/Down field with respect to LLH. |
|||||||||
| var | #zOffset down |
fp32_t |
m | – | The Down offset of the North/East/Down field with respect to LLH. |
|||||||||
| var | #phiRotation over x axis |
fp32_t |
rad | −π … π | The phi Euler angle from the vehicle's attitude. |
|||||||||
| var | #thetaRotation over y axis |
fp32_t |
rad | −π/2 … π/2 | The theta Euler angle from the vehicle's attitude. |
|||||||||
| var | #psiRotation over z axis |
fp32_t |
rad | −π … π | The psi Euler angle from the vehicle's attitude. |
|||||||||
| var | #vxGround Velocity X (North) |
fp32_t |
m/s | – | Ground Velocity xx axis velocity component. |
|||||||||
| var | #vyGround Velocity Y (East) |
fp32_t |
m/s | – | Ground Velocity yy axis velocity component. |
|||||||||
| var | #vzGround Velocity Z (Down) |
fp32_t |
m/s | – | Ground Velocity zz axis velocity component. |
|||||||||
| var | #pAngular Velocity in x |
fp32_t |
rad/s | −π … π | The angular velocity over body-fixed xx axis (roll). |
|||||||||
| var | #qAngular Velocity in y |
fp32_t |
rad/s | −π … π | The angular velocity over body-fixed yy axis (pitch). |
|||||||||
| var | #rAngular Velocity in z |
fp32_t |
rad/s | −π … π | The angular velocity over body-fixed zz axis (yaw). |
|||||||||
| var | #svxStream Velocity X (North) |
fp32_t |
m/s | – | Stream Velocity xx axis velocity component. |
|||||||||
| var | #svyStream Velocity Y (East) |
fp32_t |
m/s | – | Stream Velocity yy axis velocity component. |
|||||||||
| var | #svzStream Velocity Z (Down) |
fp32_t |
m/s | – | Stream Velocity zz axis velocity component. |